Blink: your first sketch
Make an LED module and the Uno's own L LED take turns every half second. Your first sketch, in the simulator and on a real board.
Start buildingIn the simulator
Complete robots, step by step: parts, wiring, code and fixes. Build each one in the simulator first.
Make an LED module and the Uno's own L LED take turns every half second. Your first sketch, in the simulator and on a real board.
Build the CoreEngine robot car and make it drive a square: four straight sides and four right turns, timed with delay(). Then tune the turns.
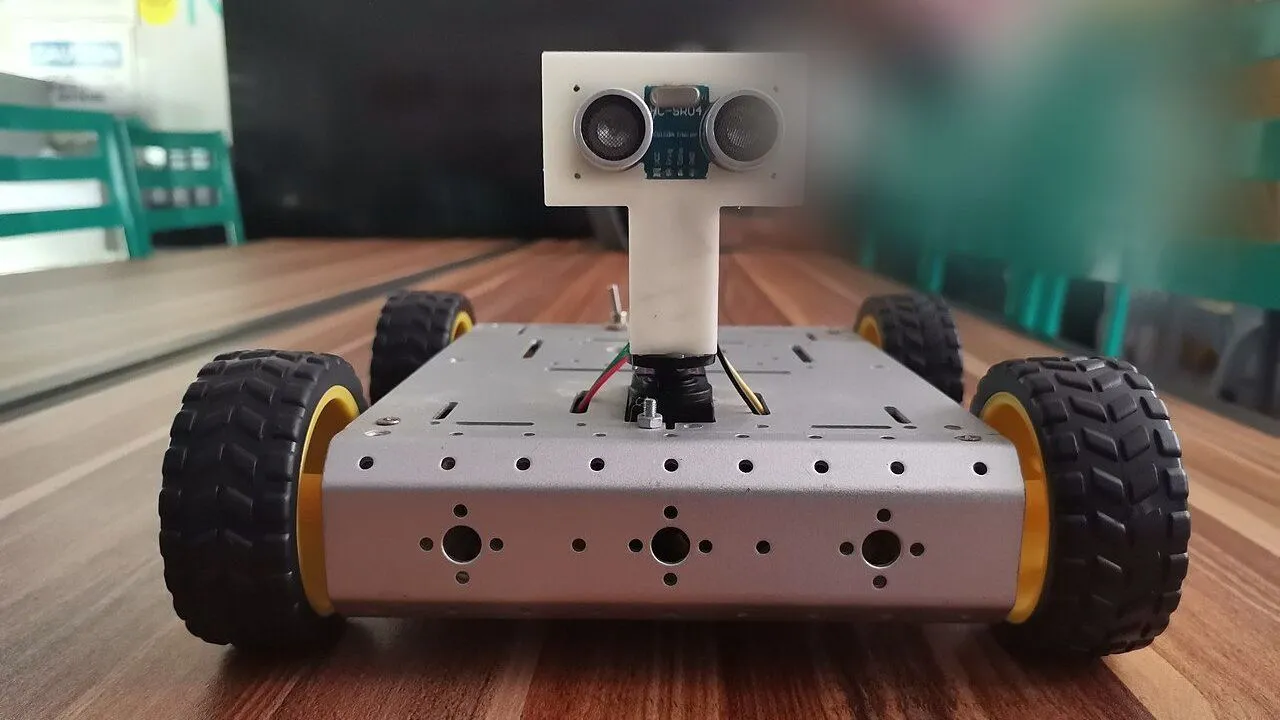
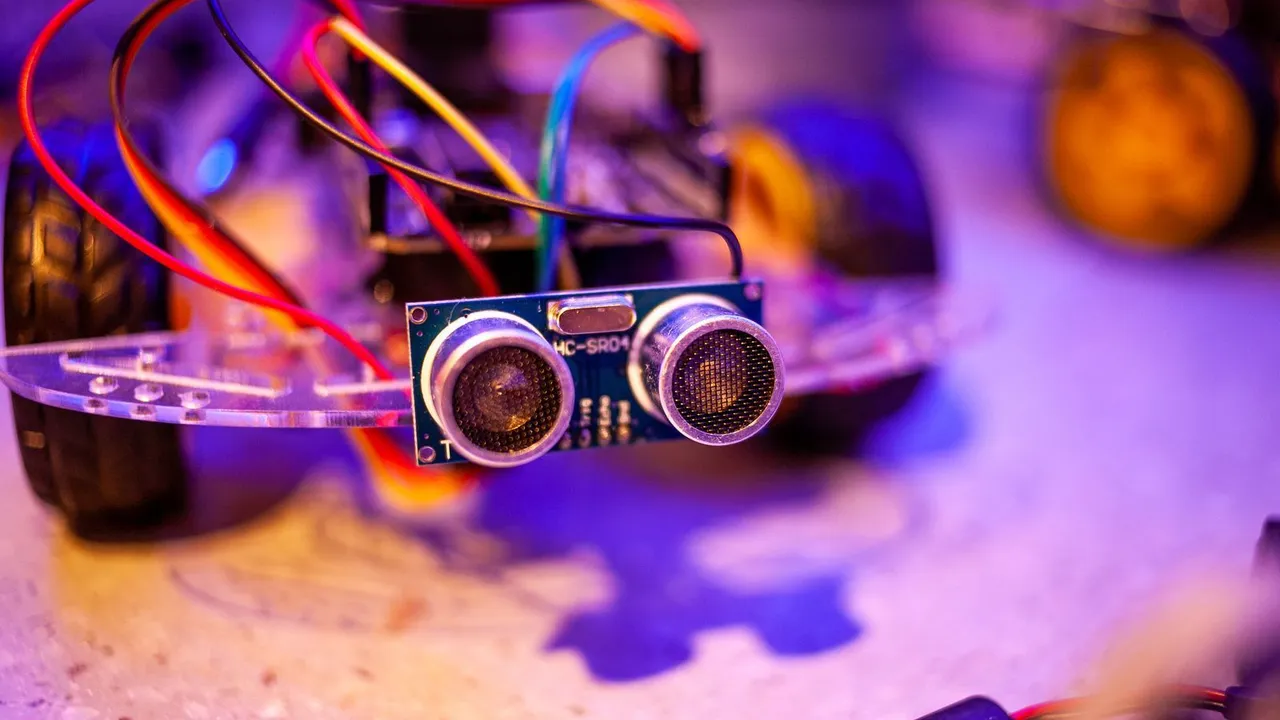
The car gets an HC-SR04 ultrasonic sensor. It drives ahead, and when something is closer than 25 cm, it drives backwards, turns right and drives forward again.
The car stays 20 cm away from whatever is in front of it and follows it when it moves. Your first proportional (P) controller, tuned while you watch the Serial Monitor.
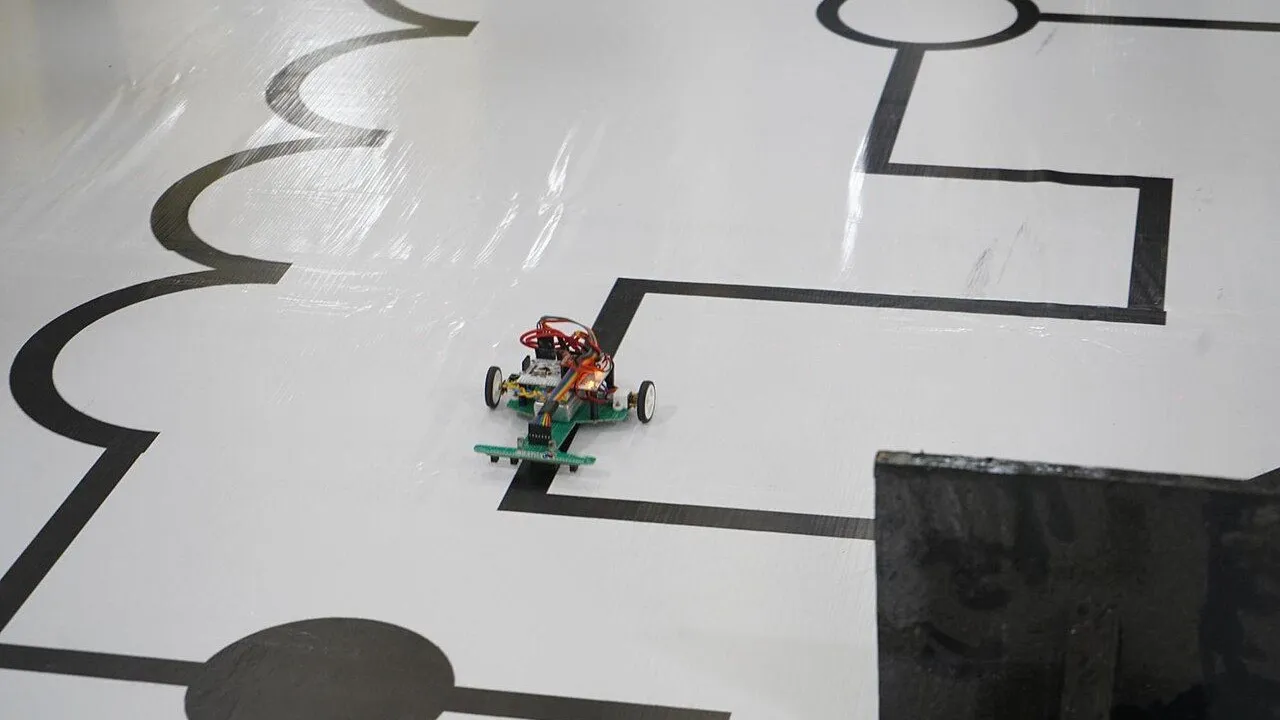
Two IR line sensors under the front let the car follow a black line on a white floor. Learn how the sensors tell black from white and how four cases steer.